Thanks, been at it for a couple of years. Thought I might find some crossover here. The XY table support flexure mechanism is something I'm quite proud of. Single piece, print-in-place.
1
Vik Olliver
Thanks, been at it for a couple of years. Thought I might find some crossover here. The XY table support flexure mechanism is something I'm quite proud of. Single piece, print-in-place.
@Vik Olliver Yeah I'm looking forward to the hexapod evolution of this one; sadly it seems none of the work towards that has yet been shared and starting from scratch is a lil bit much https://github.com/0x23/MicroManipulatorStepper/issues/19
So I'm quite interested in this. Mostly because I have dreamed for a while to get a 6-dof manipulator and let's be honest. A hexapod is a pipe dream unless you are filthy rich. So I would l...
11:39 p.m.
(A major goal I have there is to be able to assemble flip-chip-dies with the pad density limitations being only negligibly affected by the closed-loop accuracy capabilities of the motion platform.)
namibj
(A major goal I have there is to be able to assemble flip-chip-dies with the pad density limitations being only negligibly affected by the closed-loop accuracy capabilities of the motion platform.)
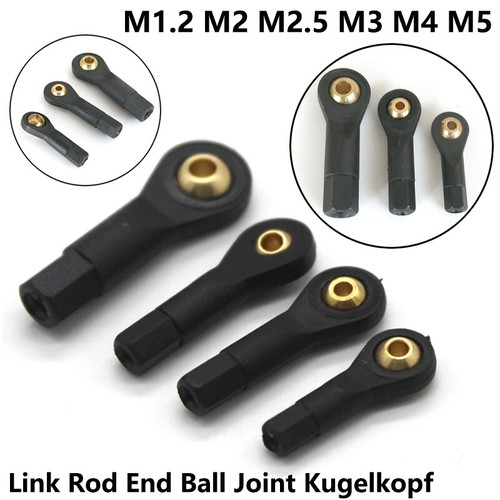
Yes I have, but they seem to have too much friction for precision applications or induce play if they are manufactured with a loose fit.
This one in particular regarding these makes me wonder if the DIY porous graphite block spherical air bearings AppliedScience demonstrated a few years back would scale/be approriate, as AFAIK those can be set up to have no stiction and the air in the gap acts first order as a pretty linear spring which would imply decently behaved kinematic modeling and should at least for sufficiently limited-required-stiffness applications provide acceptable "lack of wiggle/play".....
Vik Olliver
Well the actuator for the μRepRap is modular, and I am thinking of 6 DoF...
YAY.
I'm assuming it's quite possibly better suited for this kind of task?
Given that we're not really looking at sub-micron positioning for die-assembly, but rather efective closed-loop-operation for low single digit micron accuracy?
11:51 p.m.
Also Z conveninetly is much tamer in distance requirements and can likley use a lot of force-control motion for at least corase movement/until-touch to sort of "home" itself to a position right where it's touching and then hold while e.g. resin hardens or e.g. move a defined small distance further to compress ACF (anisotropic conductive film) tape or squash down sintering paste or such....
namibj
Yes I have, but they seem to have too much friction for precision applications or induce play if they are manufactured with a loose fit.
This one in particular regarding these makes me wonder if the DIY porous graphite block spherical air bearings AppliedScience demonstrated a few years back would scale/be approriate, as AFAIK those can be set up to have no stiction and the air in the gap acts first order as a pretty linear spring which would imply decently behaved kinematic modeling and should at least for sufficiently limited-required-stiffness applications provide acceptable "lack of wiggle/play".....
 1

 https://github.com/0x23/MicroManipulatorStepper/issues/19